James Hermus
SNSF Ambizione Fellow and Principal Investigator, Idiap Research Institute · Martigny, Switzerland
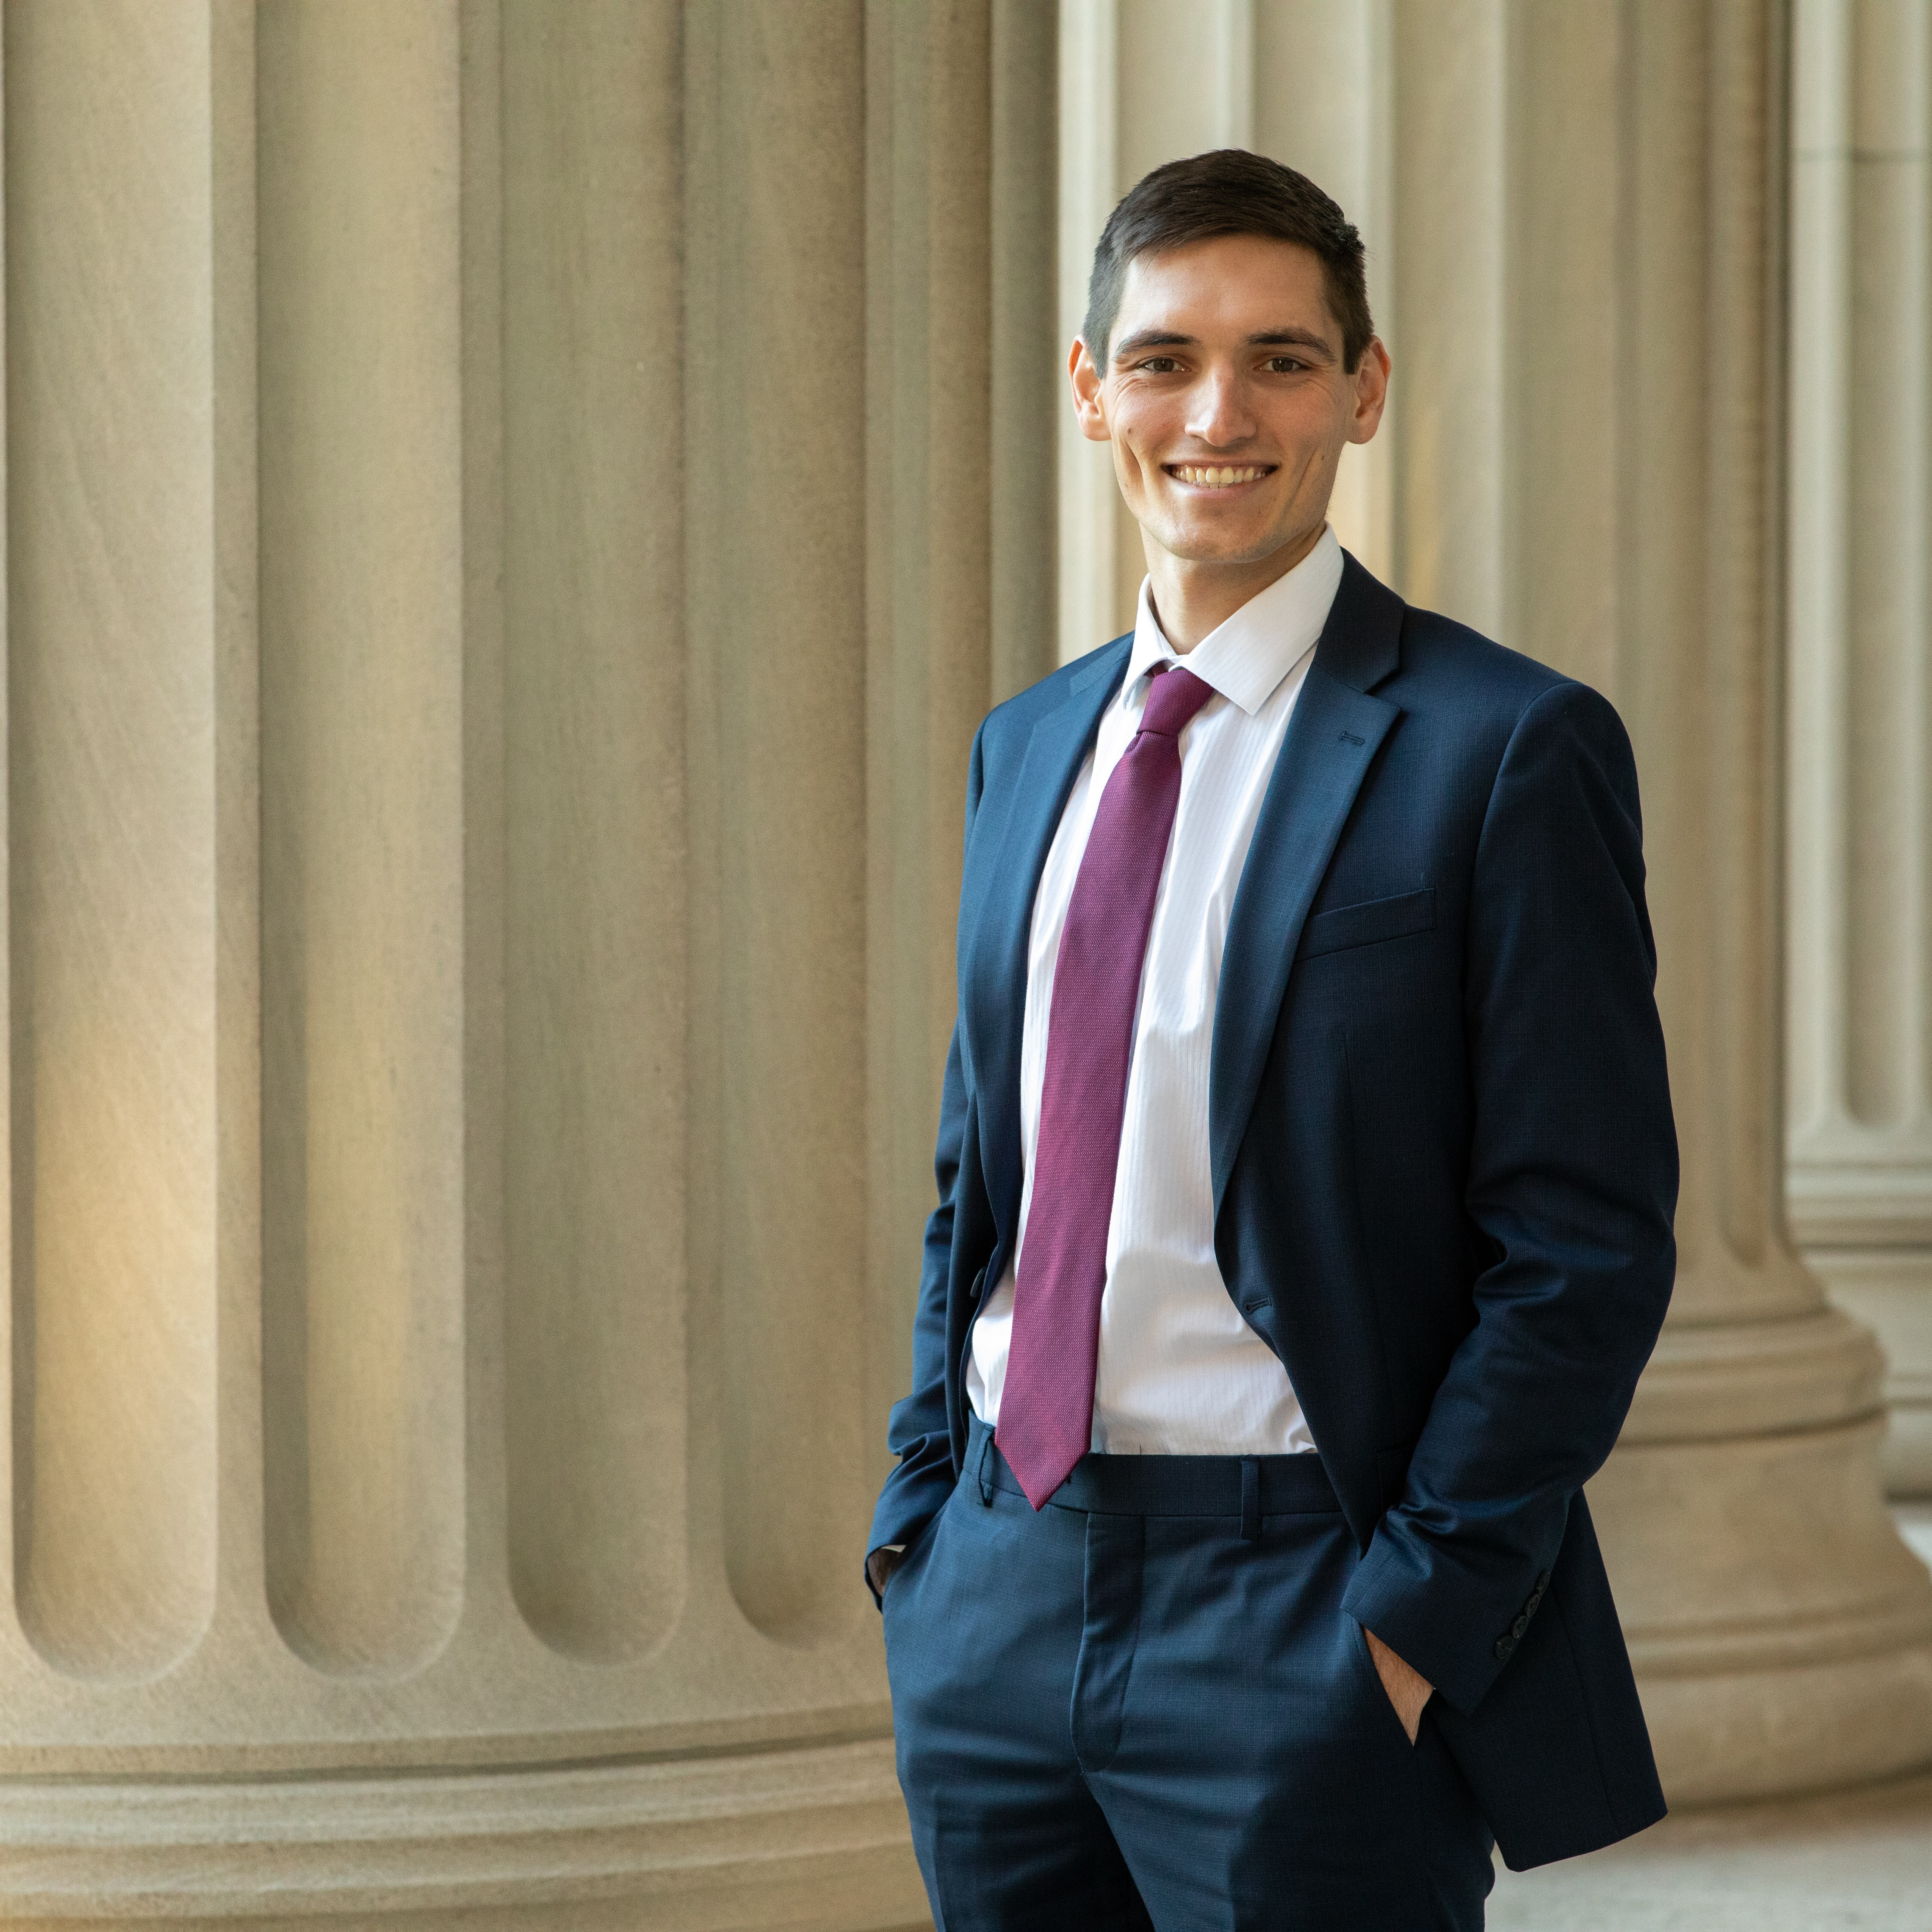
As a researcher, James develops descriptive models of human motor control in tasks that involve substantial force and motion – physical interaction tasks. His work stems from a unique perspective heavily grounded in physical modeling and control theory. By studying the quirks of the human motor system, his prior research has provided insight into the control mechanisms behind human physical interaction. His current research, as part of the Ambizione project, aims to ask further scientific questions about how humans manage contact, and engineering questions about how these ideas can be applied to robotics.
More about James’s training and research career is on the biography page.
Research Interests
- Physical interaction -- tasks with substantial force and motion
- Kinematic redundancy
- System identification of mechanical impedance
News
| Sep 30, 2026 | Preprint posted to arXiv, “Identifiable Decomposition of Submovements in Human Hand Trajectories” by Adrian Prados, James Hermus, Ramon Barber, and Sylvain Calinon. Now available at [Link]. |
|---|---|
| Sep 24, 2026 | Preprint posted to ChemRxiv, “ARMS: an Automated Robotized human-Mimicking Solid sampling system” by Jasper Tan, James Hermus, Emmanuel Senft, Sylvain Calinon, and Pascal Miéville. Now available at [Link]. |
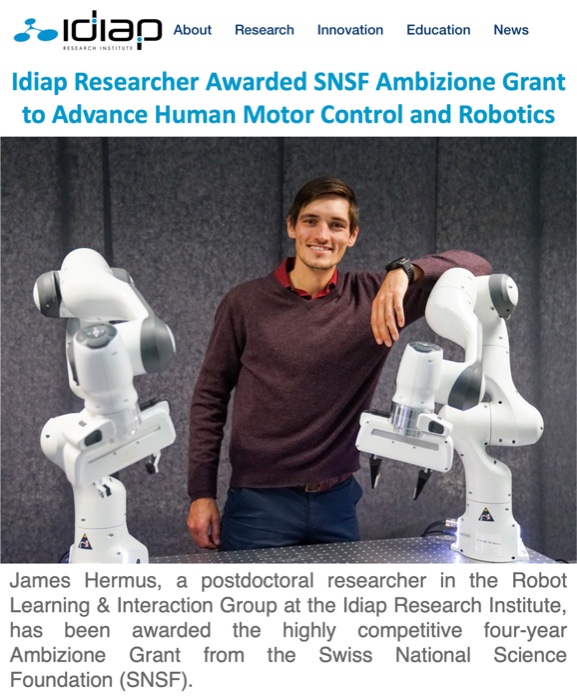
| Sep 1, 2026 | Today I begin as an SNSF Ambizione Fellow and Principal Investigator at the Idiap Research Institute, marking the official start of my four-year project, Confronting the Paradox of Human Motor Control – Leveraging Subtractive and Generative Models, in collaboration with Sylvain Calinon (Idiap) and Auke Ijspeert (EPFL). I am delighted that Andrés Blanco joins as my first PhD student. |
| Jul 24, 2026 | Visited Boston to celebrate the retirement of my doctoral advisor, Professor Neville Hogan. It was a pleasure presenting a bit about my research direction, catching up with former colleagues from the Newman Laboratory, and meeting many of the other students Neville has advised across four decades. |
| Jul 14, 2026 | Congratulations to Victor Dubois and Zixu Lu on completing their Master’s projects — Victor on diffusing elementary dynamic actions, and Zixu on ergodic search over stiffness trajectories. It was a pleasure working with them both. |
| Jun 16, 2026 | Hosted Steve Heim for a talk at Idiap. A genuine pleasure — his work on locomotion with central pattern generators connects closely to questions we are asking in the Ambizione project. |